

A2D2: Audi Autonomous Driving Dataset
Paper • 2004.06320 • Published

View on Pictograph · Pictograph Research · Instance Segmentation · RF-DETR Seg Medium · FP32 · Creative Commons Attribution-NoDerivatives 4.0
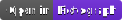
This is an instance segmentation model built on RF-DETR Seg Medium, trained on the A2D2 dataset. It expects 432x432 input and runs in FP32 precision. The ONNX weights are in this repo; run them with the Pictograph SDK (below) or open the model on Pictograph to test it in-browser, call the hosted API, or deploy it as an always-on endpoint.
Headline: 18.9% mAP.
| Metric | Value |
|---|---|
| mAP | 18.9% |
| mAP@50 | 36.8% |
Class index matches the model's output order.
| # | Class |
|---|---|
| 0 | car |
| 1 | pedestrian |
| 2 | truck |
| 3 | small vehicle |
| 4 | utility vehicle |
| 5 | bicycle |
| Setting | Value |
|---|---|
| Base dataset | A2D2 |
| Dataset size | 12,758 images |
| Input size | 432x432 |
| Epochs | 10 |
| Batch size | 4 |
| Learning rate | 0.0002 |
| Model size | medium |
| Precision | FP32 |
| Version | 1.0.0 |
The weights ship as ONNX (pg-streetparse-m.onnx) with a config.json. The Pictograph SDK applies the model's exact pre/post-processing for you:
pip install "pictograph[inference]"
from huggingface_hub import hf_hub_download
from pictograph import load_model, InstanceSegmentationModel

onnx = hf_hub_download("pictograph/pg-streetparse-m", "pg-streetparse-m.onnx")
config = hf_hub_download("pictograph/pg-streetparse-m", "config.json")

model: InstanceSegmentationModel = load_model(onnx, config, task="instance_segmentation")
result = model.predict("photo.jpg")   # InstanceSegmentationResult
for p in result.polygons:              # instances whose mask polygonized
    b = p.bounding_box
    ring = p.polygon.paths[0]          # outer ring: [{'x','y'}, ...]
    print(f"{p.name} {p.confidence:.2f} {len(ring)}-pt mask "
          f"box=({b.x:.0f},{b.y:.0f},{b.w:.0f},{b.h:.0f})")
Example output (illustrative; your exact values depend on the image):
car 0.91 48-pt mask box=(118,86,140,210)
pedestrian 0.87 52-pt mask box=(120,250,132,300)
from huggingface_hub import hf_hub_download
import onnxruntime as ort

onnx = hf_hub_download("pictograph/pg-streetparse-m", "pg-streetparse-m.onnx")
sess = ort.InferenceSession(onnx, providers=["CPUExecutionProvider"])
inp = sess.get_inputs()[0]
print(inp.name, inp.shape)   # NCHW float32; input size + normalization in config.json
# outputs = sess.run(None, {inp.name: preprocessed_batch})
# Decoding is architecture-specific; the Pictograph SDK (above) does it for you.
Released under Creative Commons Attribution-NoDerivatives 4.0, the license of its training data, A2D2. Commercial use is permitted with attribution: when you use this model, please credit Audi AG (Geyer et al., 2020).
This model uses the RF-DETR Seg Medium architecture:
@inproceedings{robinson2026rfdetr,
  title     = {RF-DETR: Real-Time Detection Transformer},
  author    = {Robinson, Isaac and Robicheaux, Peter and Popov, Matvei and Ramanan, Deva and Peri, Neehar},
  booktitle = {International Conference on Learning Representations (ICLR)},
  year      = {2026},
  url       = {https://arxiv.org/abs/2511.09554}
}
It was trained on A2D2, from:
@article{geyer2020a2d2,
  title = {{A2D2}: {Audi Autonomous Driving Dataset}},
  author = {Geyer, Jakob and Kassahun, Yohannes and Mahmudi, Mentar and Ricou, Xavier and Durgesh, Rupesh and Chung, Andrew S. and Hauswald, Lorenz and Pham, Viet Hoang and M{\"u}hlegg, Maximilian and Dorn, Sebastian and Fernandez, Tiffany and J{\"a}nicke, Martin and Mirashi, Sudesh and Savani, Chiragkumar and Sturm, Martin and Vorobiov, Oleksandr and Oelker, Martin and Garreis, Sebastian and Schuberth, Peter},
  journal = {arXiv preprint arXiv:2004.06320},
  year = {2020}
}
Trained and published with Pictograph - annotate, train, and deploy from one API.
Base model
Roboflow/rf-detr-seg-medium