| --- |
| license: apache-2.0 |
| base_model: Kevin-thu/Epona |
| tags: |
| - robotics |
| - autonomous-driving |
| - computer-vision |
| - world-model |
| - trajectory-planning |
| --- |
| |
| # SimVTA: Simulation-Grounded Video-Trajectory Alignment for Driving World Action Models |
|
|
| [](https://arxiv.org/abs/2610.13781) |
| [](https://opendrivelab.com/SimVTA/) |
| [](https://github.com/OpenDriveLab/SimVTA) |
|
|
| > [Changhui Jing](https://scholar.google.com/citations?user=B4Nu6pAAAAAJ), [Haochen Tian](https://scholar.google.com/citations?user=DoyuNwEAAAAJ), [Hongchen Li](https://scholar.google.com/citations?user=QO6p6OgAAAAJ), [Tianyu Li](https://sephyli.github.io/), [Caojun Wang](https://scholar.google.com/citations?user=35xHlDUAAAAJ), |
| > [Zihao Zhang](https://scholar.google.com/citations?user=R2Brvm4AAAAJ), [Yanhao Liu](https://scholar.google.com/citations?user=dYicC-4AAAAJ), [Chengen Xie](https://scholar.google.com/citations?user=q0W3n-cAAAAJ), [Bailin Li](https://www.linkedin.com/in/libailin/), [Hao Zhao](https://sites.google.com/view/fromandto), [Zhenjie Yang](https://scholar.google.com/citations?user=jVlRiUEAAAAJ) |
| --- |
|
|
|  |
|
|
|
|
| ## Highlights |
|
|
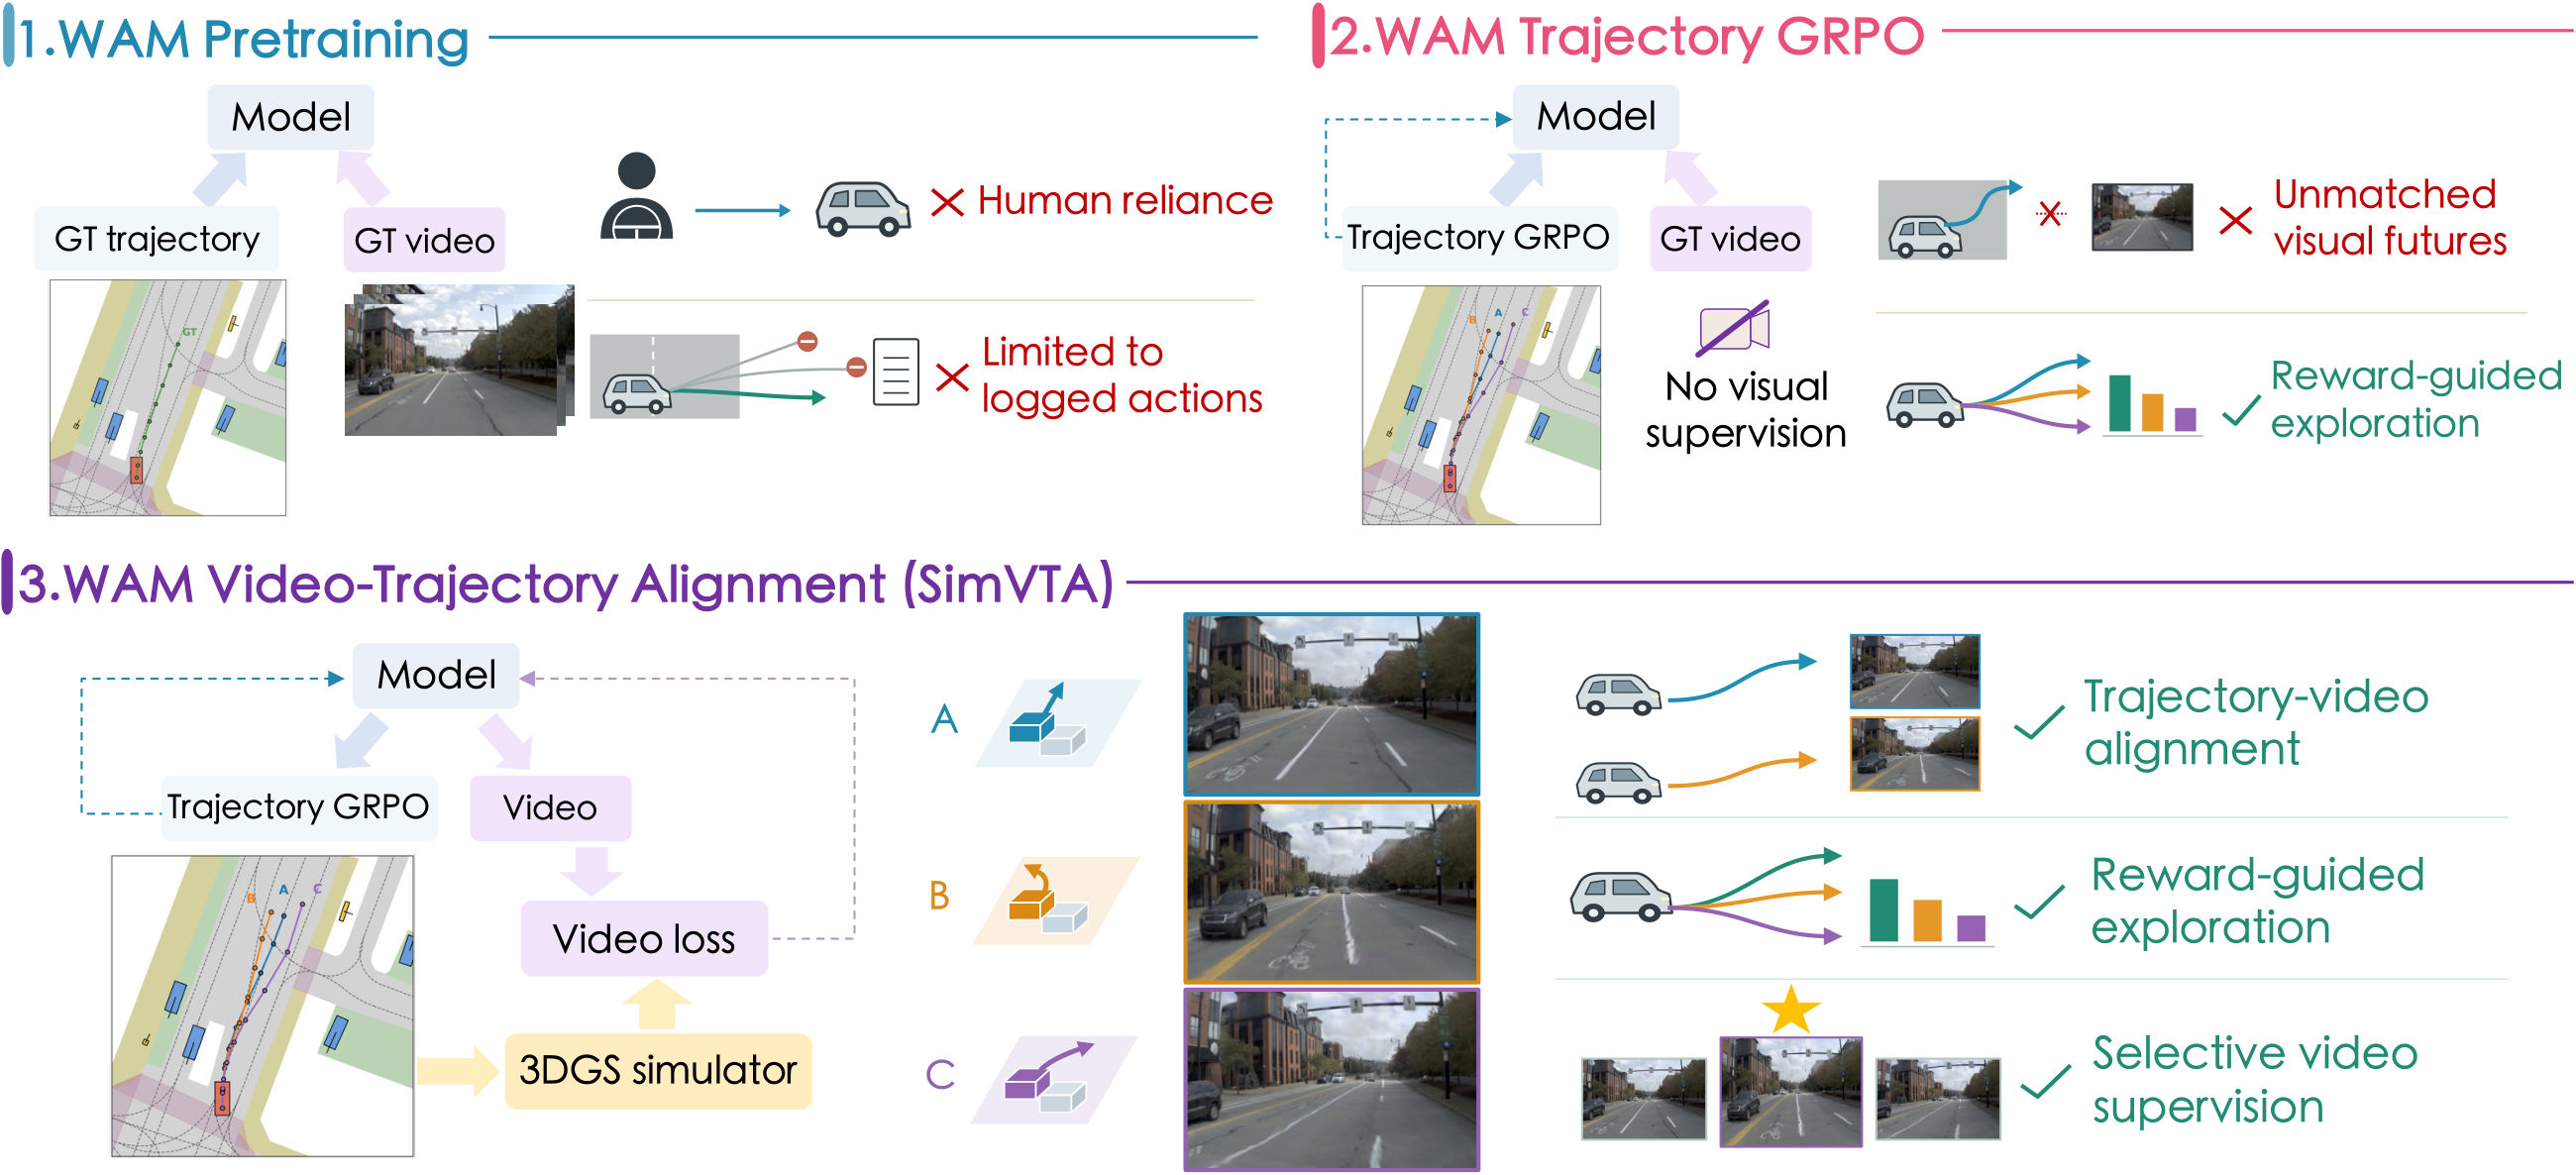
| - 🚗 **Simulation-grounded alignment:** Render matched future videos for alternative candidate trajectories in reconstructed real-world scenes. |
| - 🔍 **Selective video supervision:** Prioritize higher-error futures among high-reward candidates and jointly train trajectory planning and video prediction. |
| - 📈 **Improved planning:** Achieve 91.3 PDMS on NAVSIM v1, 88.2 EPDMS on NAVSIM v2, and 38.8 average HD-Score on HUGSIM, with direct trajectory prediction at inference. |
|
|
| ## Overview |
|
|
| **SimVTA** is a simulation-grounded post-training framework for driving world action models. It extends supervision beyond logged trajectories using a 3D Gaussian Splatting simulator, combining trajectory GRPO with a flow-matching video loss that updates shared representations. |
|
|
| Reported results in the paper: |
|
|
| | Benchmark | Metric | SimVTA | |
| | --- | --- | --- | |
| | NAVSIM v1 | PDMS | **91.3** (+5.1 over the 86.2 initialization) | |
| | NAVSIM v2 | EPDMS | **88.2** | |
| | HUGSIM | Average HD-Score | **38.8** | |
|
|
| ## Matched Futures for Alternative Actions |
|
|
|  |
|
|
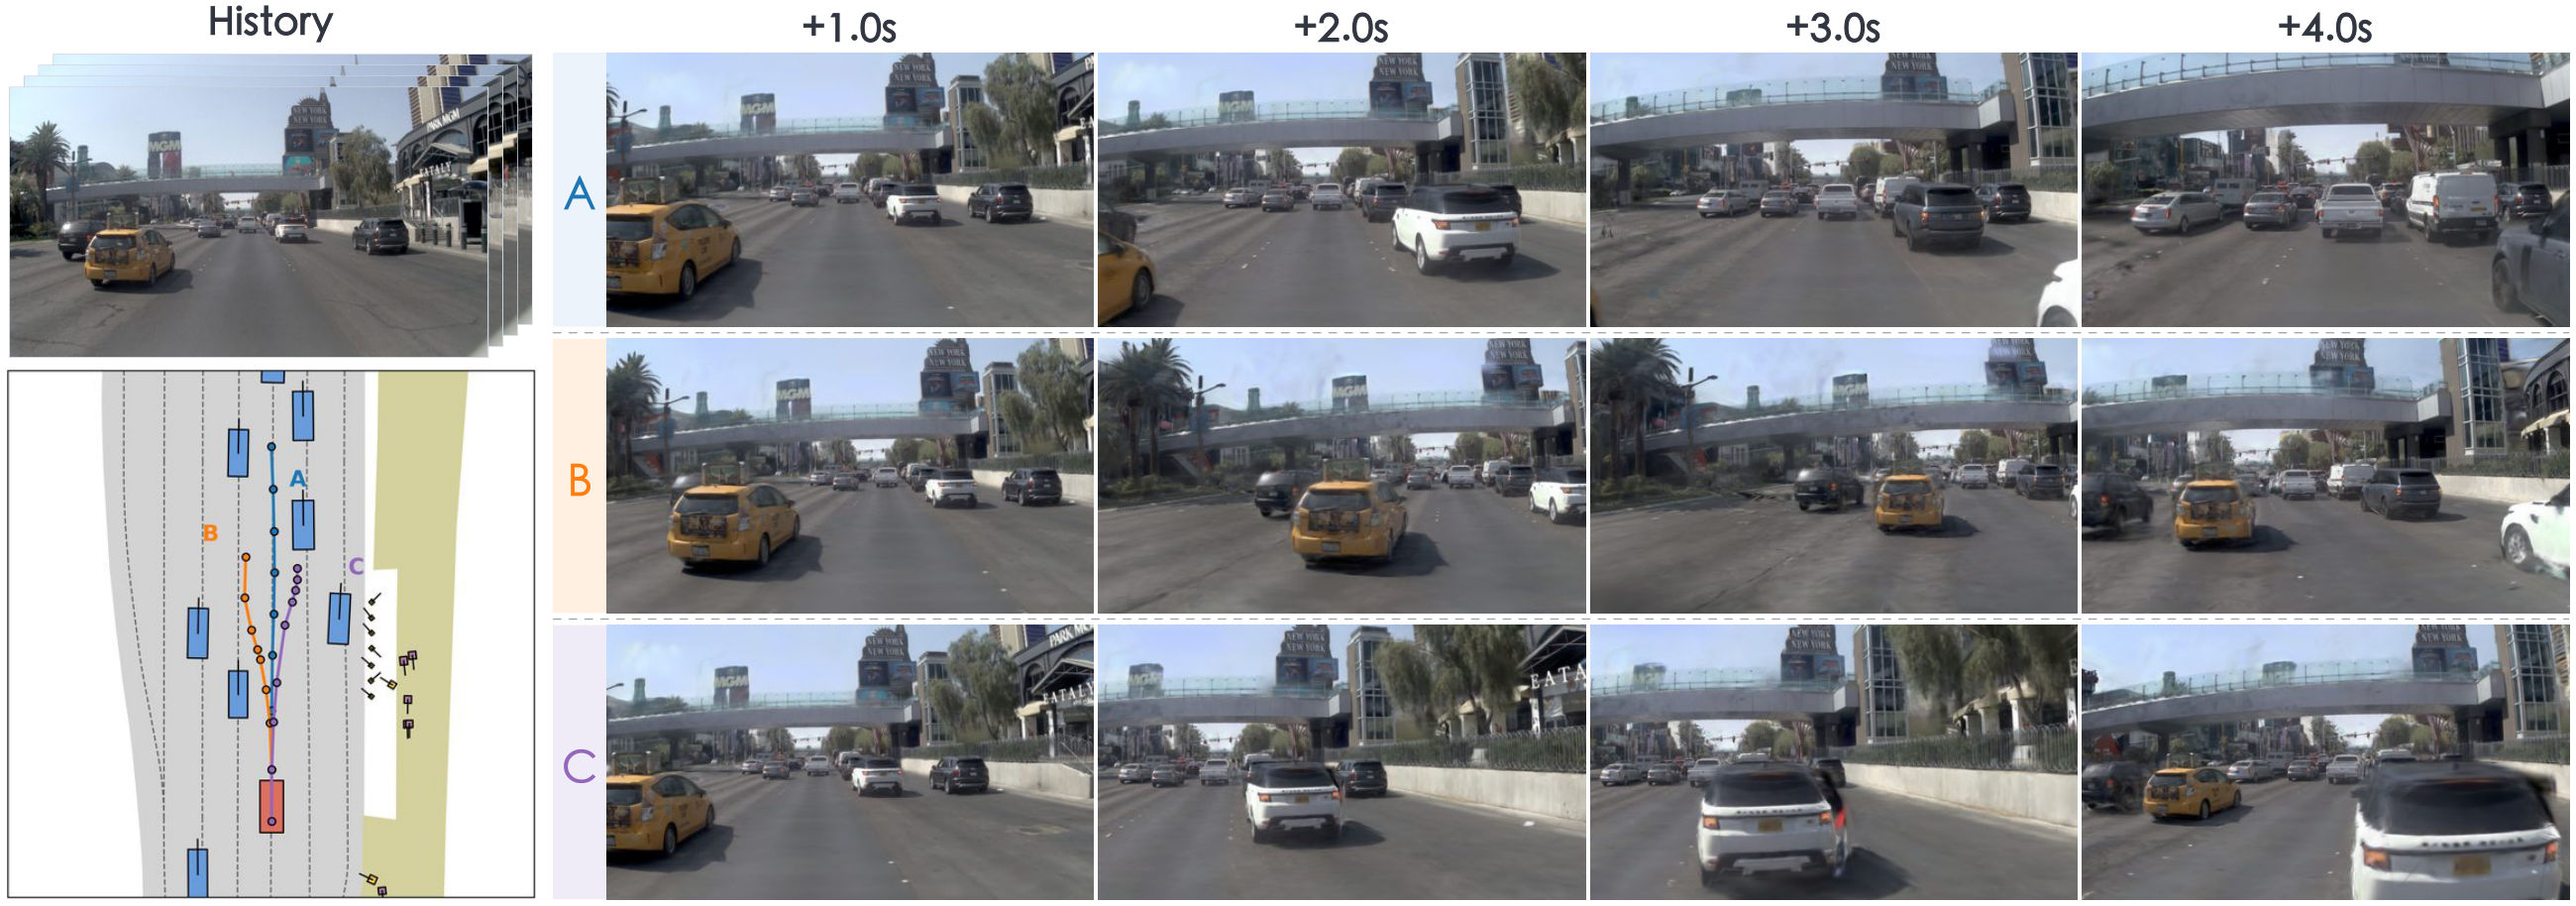
| **Simulator-rendered futures for going straight (A), changing lanes left (B), and changing lanes right (C).** |
|
|
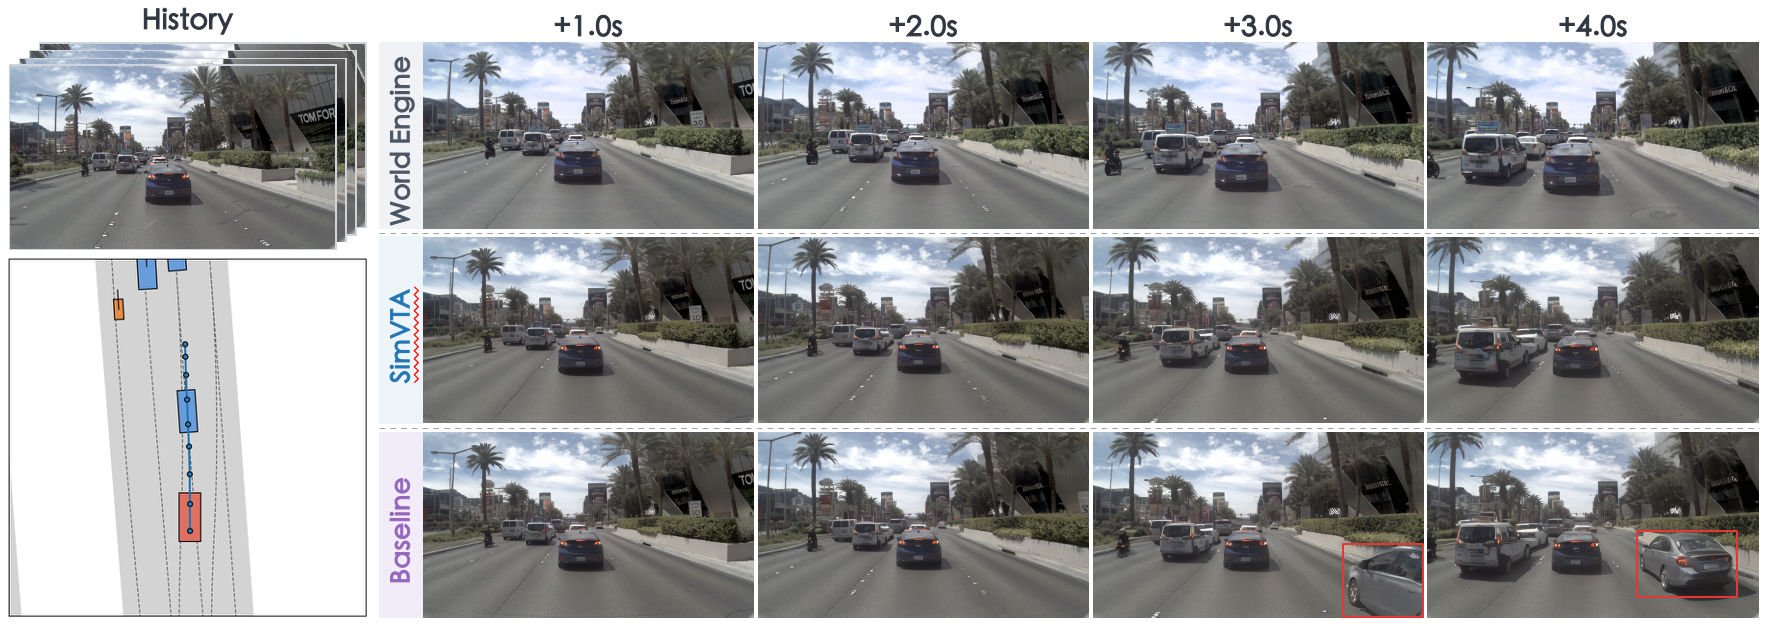
| ## Video-Trajectory Alignment |
|
|
|  |
|
|
| **Video-trajectory alignment: World Engine renderings compared with SimVTA and Epona predictions.** |
|
|
| ## Checkpoint Download |
|
|
| This repository provides `simvta.pkl`, the SimVTA checkpoint post-trained from a NAVSIM-adapted [Epona](https://huggingface.co/Kevin-thu/Epona) initialization. |
|
|
| ```bash |
| pip install -U huggingface_hub |
| hf download OpenDriveLab-org/SimVTA simvta.pkl --local-dir ./ckpts |
| ``` |
|
|
| The checkpoint will be saved to `./ckpts/simvta.pkl`. Code and detailed inference instructions are being prepared for release in the [GitHub repository](https://github.com/OpenDriveLab/SimVTA). Additional pretrained components and dataset preparation will be documented there. |
|
|
| ## Acknowledgements |
|
|
| We thank the authors and open-source contributors of the following projects for providing the models, simulation tools, and evaluation benchmarks that support this work: |
|
|
| - [Epona](https://github.com/Kevin-thu/Epona) | [World Engine](https://github.com/OpenDriveLab/WorldEngine) | [NAVSIM](https://github.com/autonomousvision/navsim) | [HUGSIM](https://github.com/hyzhou404/HUGSIM) |
|
|
| We also thank the broader open-source community for its contributions to driving world models, autonomous driving, and 3D Gaussian Splatting. |
|
|
| ## License and Citation |
|
|
| The SimVTA release is licensed under [Apache-2.0](LICENSE), subject to the retained upstream MIT notice for Epona in [THIRD_PARTY_NOTICES.md](THIRD_PARTY_NOTICES.md). |
|
|
| If our paper or checkpoint helps your research, please consider citing [our work](https://arxiv.org/abs/2610.13781) and giving the [GitHub repository](https://github.com/OpenDriveLab/SimVTA) a star. |
|
|