


license: other
license_name: non-commercial-research
base_model: alibaba-pai/Wan2.2-Fun-5B-Control
tags:
  - autonomous-driving
  - video-generation
  - world-model
  - closed-loop-simulation
DreamStream: Towards Policy-Oriented Generative Simulation for End-to-End Driving
CoRL 2026 · Paper · Project Page · Code
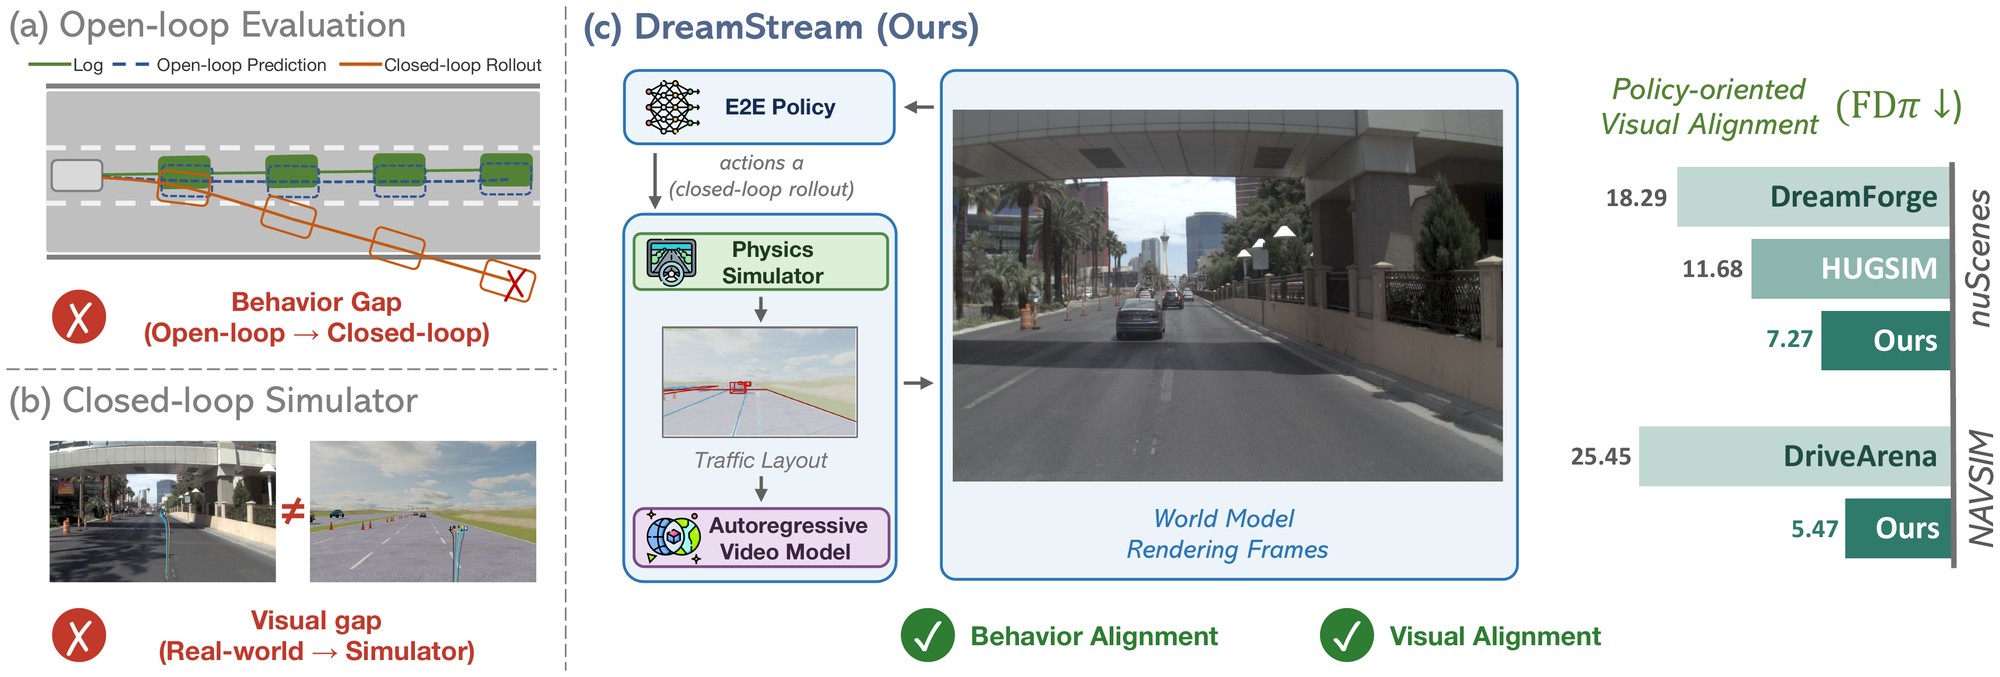
DreamStream is a generative closed-loop simulator for end-to-end driving policies. A physics simulator executes the policy's plan and renders traffic layouts; a few-step autoregressive video model turns those layouts into camera frames that the policy consumes in the next step.
This repository hosts the checkpoints. Code, setup and usage instructions are on GitHub.
Contents
| Path | Description |
|---|---|
video_model/wan2.2-5b-nuplan-train-v1/ema_model.pt |
DreamStream video generation model (Wan2.2-Fun-5B-Control backbone, 1280×704), trained on nuPlan |
policy/ |
Front-camera end-to-end driving policies (DiffusionDrive, DiffusionDriveV2, DrivoR, LTF, SparseDriveV2) used for closed-loop evaluation in BridgeSim and for the FDπ metric |
policy/aux/ |
Auxiliary files required by the policies (trajectory k-means anchors) |
The base model (alibaba-pai/Wan2.2-Fun-5B-Control) is not redistributed here; the inference server downloads it automatically.
Usage
The video model checkpoint is downloaded automatically by the inference server; see the GitHub READMEs for where the policy checkpoints go. To fetch everything manually:
hf download UCLA-VAIL/DreamStream --local-dir DreamStream-ckpts
See the GitHub repository for how to run the video model server, closed-loop evaluation in BridgeSim, and FDπ.
License
The checkpoints are released for non-commercial research use only. See the GitHub repository for code licenses and third-party notices.
Citation
@inproceedings{leng2026dreamstream,
  title     = {{DreamStream: Towards Policy-Oriented Generative Simulation for End-to-End Driving}},
  author    = {Leng, Ziyang and Mo, Sicheng and Zhao, Seth Z. and Cai, Haoyuan and Zeng, Yu and McAllister, Rowan and Zhou, Bolei},
  booktitle = {Conference on Robot Learning (CoRL)},
  year      = {2026}
}