| --- |
| license: other |
| license_name: non-commercial-research |
| base_model: alibaba-pai/Wan2.2-Fun-5B-Control |
| tags: |
| - autonomous-driving |
| - video-generation |
| - world-model |
| - closed-loop-simulation |
| --- |
| |
| # DreamStream: Towards Policy-Oriented Generative Simulation for End-to-End Driving |
|
|
| **CoRL 2026** · [Paper](https://arxiv.org/abs/2609.26792) · [Project Page](https://vail-ucla.github.io/DreamStream/) · [Code](https://github.com/VAIL-UCLA/DreamStream) |
|
|
|  |
|
|
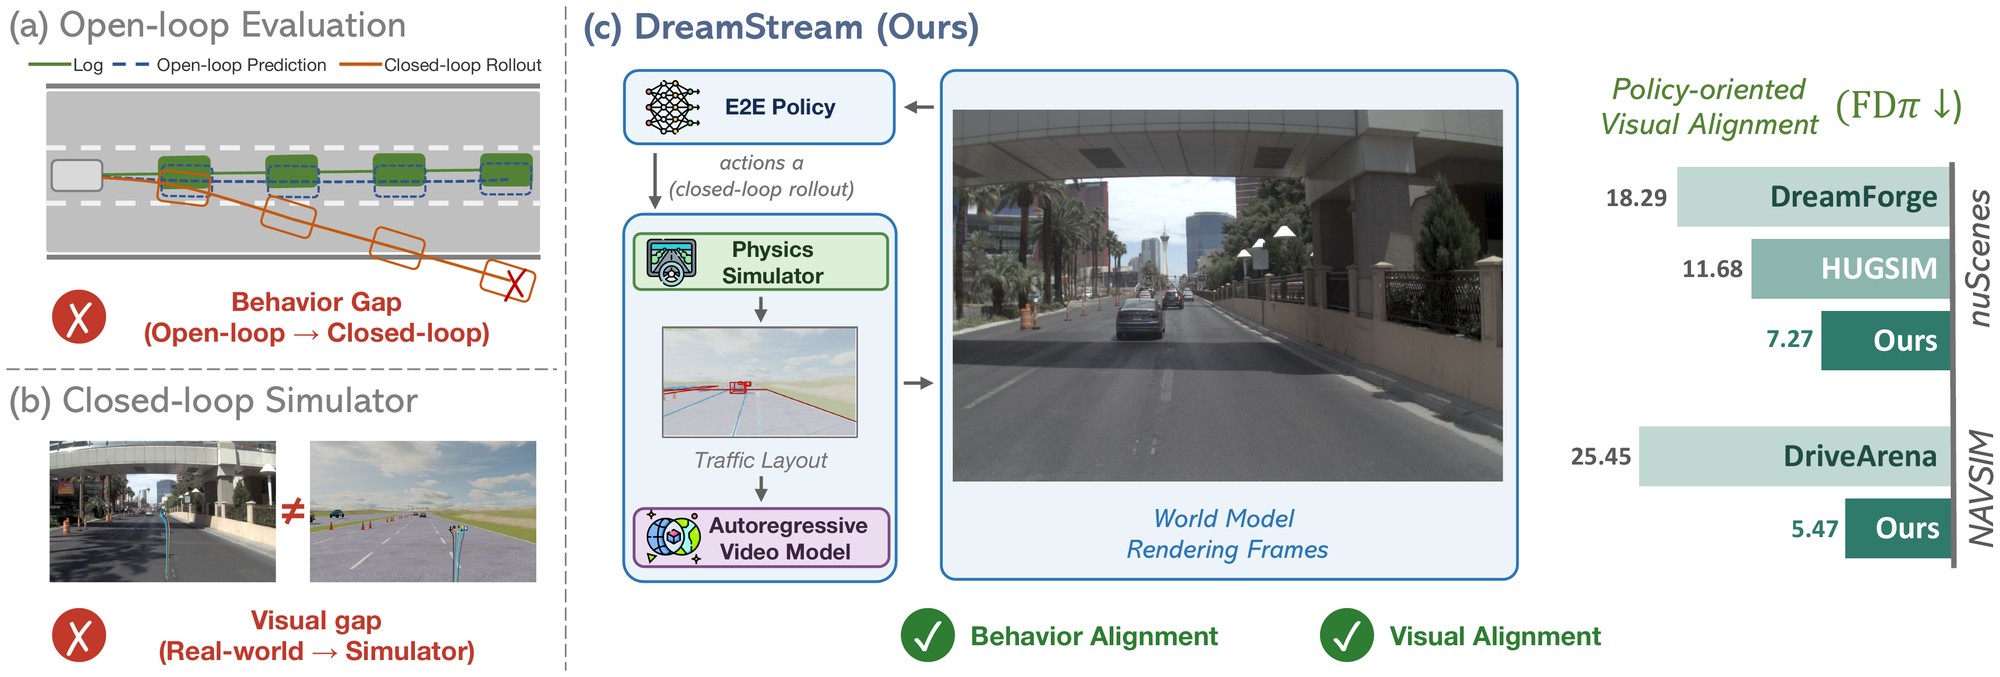
| DreamStream is a generative closed-loop simulator for end-to-end driving |
| policies. A physics simulator executes the policy's plan and renders traffic |
| layouts; a few-step autoregressive video model turns those layouts into camera |
| frames that the policy consumes in the next step. |
|
|
| This repository hosts the checkpoints. Code, setup and usage instructions are |
| on [GitHub](https://github.com/VAIL-UCLA/DreamStream). |
|
|
| ## Contents |
|
|
| | Path | Description | |
| |---|---| |
| | `video_model/wan2.2-5b-nuplan-train-v1/ema_model.pt` | DreamStream video generation model (Wan2.2-Fun-5B-Control backbone, 1280×704), trained on nuPlan | |
| | `policy/` | Front-camera end-to-end driving policies (DiffusionDrive, DiffusionDriveV2, DrivoR, LTF, SparseDriveV2) used for closed-loop evaluation in BridgeSim and for the FDπ metric | |
| | `policy/aux/` | Auxiliary files required by the policies (trajectory k-means anchors) | |
|
|
| The base model ([alibaba-pai/Wan2.2-Fun-5B-Control](https://huggingface.co/alibaba-pai/Wan2.2-Fun-5B-Control)) |
| is not redistributed here; the inference server downloads it automatically. |
|
|
| ## Usage |
|
|
| The video model checkpoint is downloaded automatically by the inference |
| server; see the GitHub READMEs for where the policy checkpoints go. To fetch |
| everything manually: |
|
|
| ```bash |
| hf download UCLA-VAIL/DreamStream --local-dir DreamStream-ckpts |
| ``` |
|
|
| See the [GitHub repository](https://github.com/VAIL-UCLA/DreamStream) for how to |
| run the video model server, closed-loop evaluation in BridgeSim, and FDπ. |
|
|
| ## License |
|
|
| The checkpoints are released for **non-commercial research use only**. See the |
| [GitHub repository](https://github.com/VAIL-UCLA/DreamStream) for code licenses |
| and third-party notices. |
|
|
| ## Citation |
|
|
| ```bibtex |
| @inproceedings{leng2026dreamstream, |
| title = {{DreamStream: Towards Policy-Oriented Generative Simulation for End-to-End Driving}}, |
| author = {Leng, Ziyang and Mo, Sicheng and Zhao, Seth Z. and Cai, Haoyuan and Zeng, Yu and McAllister, Rowan and Zhou, Bolei}, |
| booktitle = {Conference on Robot Learning (CoRL)}, |
| year = {2026} |
| } |
| ``` |
|
|


